Projects
Two projects so far: one I'm building now, and one from a university course that I later went back to and corrected.
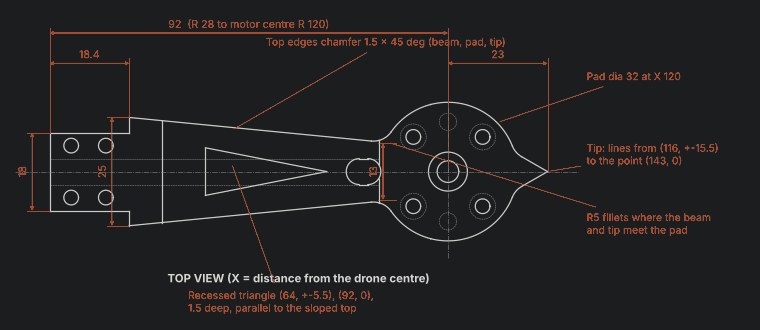 Faust v0, arm drawing
Volans v0
An autonomous drone-in-a-box system. A program running on the dock, called Base, decides where the drone should go, the drone takes off, flies the mission and lands back on its dock, which then charges it. Nobody touches it. I'm building every part with a PoliMi colleague: the airframe, a propulsion test bench, the charging dock (Base) and the software.
Read the project| Started | September 2026 |
| Vehicle | Faust v0, 5-inch quadcopter, printed PETG frame |
| Flight stack | ArduPilot, optical flow and lidar for indoor flight |
| Base | Self-centring cups with spring charging contacts |
| Software | Faust Control, Base Control (Python, MAVLink) |
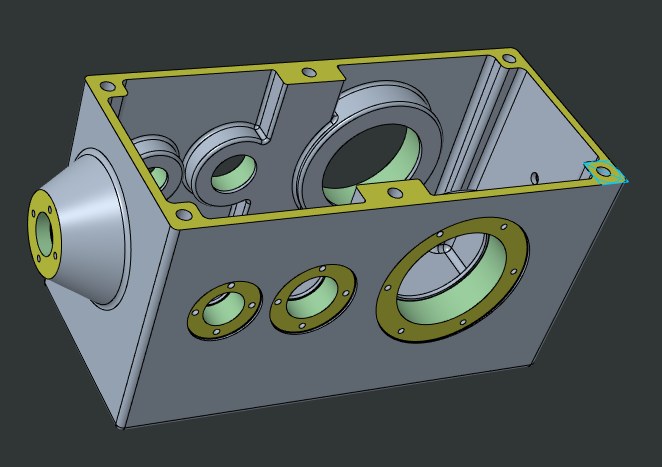 Cast housing, PTC Creo
Three-stage right-angle gear reducer
A 75 kW industrial reducer designed in a team of two for Laboratorio CAD at Politecnico di Milano: one bevel pair and two spur pairs, sized in MATLAB and modelled as a full assembly in Creo. In 2026 I re-checked the whole calculation, found errors in the force model and proposed the fixes.
Read the project| Date | June 2025, reviewed October 2026 |
| Power | 75 kW |
| Ratio | 25 : 1 (2.5 x 2.5 x 4) |
| Output | 17.4 kN·m at 40 rpm |
| Tools | MATLAB, PTC Creo |
Planned projects
Smaller projects of a few weeks each, all feeding the drone system. They are not started yet, so these pages will fill up as they get done.
Command parser
Turns a plain order like "fly 5 m left, hover 10 s, come back" into a mission file the drone can fly.
Mission safety checker
Checks every mission against a room map, height limits and the battery left, and rejects it with a reason.
Flight log analyser
A small app: drop in an ArduPilot log and get vibration, battery and tracking plots with a list of things to check.
Prop guard test
Two or three printed guard designs, compared on the bench for thrust loss and weight, plus a drop test.
Printed arm: FEM vs break test
An Abaqus model of the drone arm compared with real arms loaded to failure, varying infill and print direction.
Propeller pendulum rig
One arm with a motor on a pivot, modelled in MATLAB and tuned with PID, to learn control on a safe rig.
What I work with
The tools I use in my projects and coursework.
CAD
- SolidWorks
- PTC Creo
- Solid Edge
- Autodesk Inventor
- Technical drawing, GD&T
Programming
- Python
- MATLAB
- C, C++
- ArduPilot, MAVLink
Analysis
- Abaqus (basic FEM)
- Hand calculations
- Excel
Prototyping
- FDM printing, Bambu Lab P1S
- Functional printed parts
- Design for printing