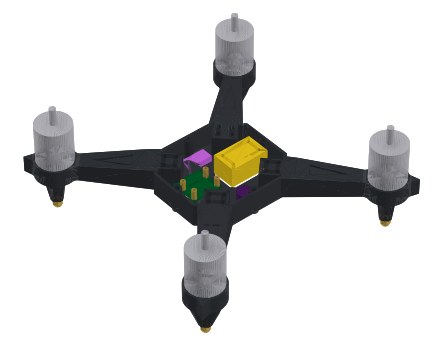
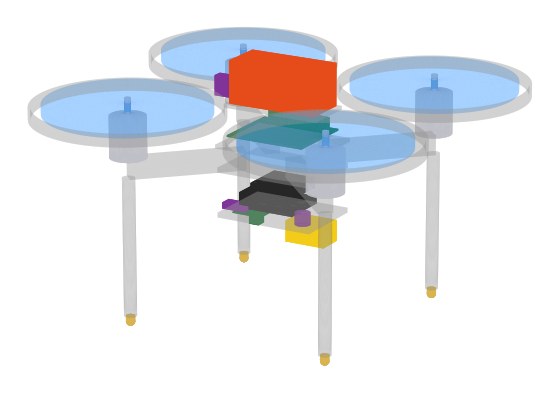
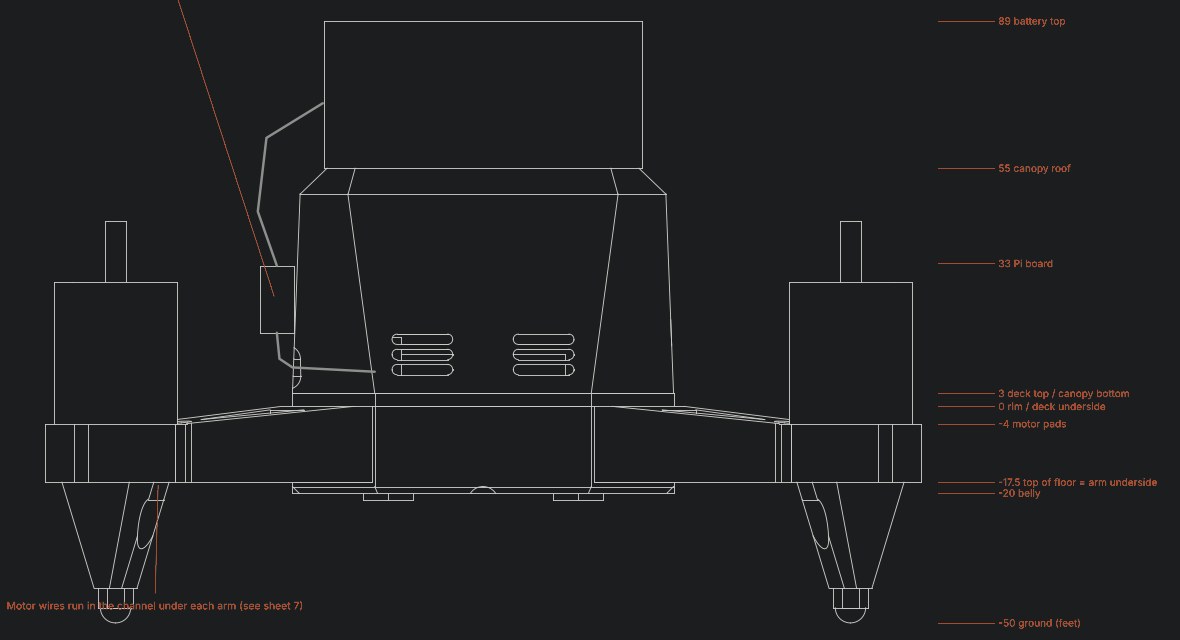
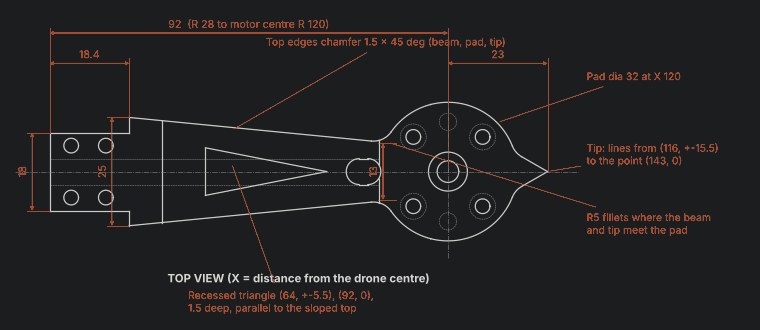
- A central body holds the electronics stack, with four separate bolt-on arms, so a broken arm is a reprint, not a new frame.
- A ring guard around each propeller and a leg under each arm tip ending in a brass foot. The feet also carry the charging current from the Base.
- ArduPilot on the flight controller, optical flow and lidar for position hold indoors with no GNSS, and a Raspberry Pi companion with a downward camera for precision landing.
| Mass | About 580 g with battery (CAD estimate) |
| Size | 5-inch props, about 33 cm across with guards |
| Targets | Thrust to weight above 2, hover of 5 min or more |
| Frame | PETG on a Bambu Lab P1S, M3 heat-set inserts |
| Motors | EMAX ECO III 2207 1900KV |
| Flight controller | MicoAir H743 V2, ArduPilot |
| Positioning | MTF-01P optical flow and lidar |
| Companion | Raspberry Pi 3 A+, Camera Module 3 |
| Battery | 4S 1500 mAh LiPo |